AUTOMOTIVE CASE STUDY

Automotive case study

One road scene.Connected sensor data.

A road-perception project shows how scene planning, object associations and issue review become an inspectable, traceable project record.

All case studies
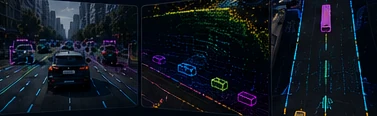
Images × point clouds · association concept
Image and point-cloud data association
12sequences
1,200Synchronized keyframe groups
4Scene types
Images and point clouds · organized by synchronized group

01 / PROJECT BRIEF

Define the task before the batch.

A perception team wants to examine scene coverage and object identities across sensors in one road-data batch. Sequences provide the structure; rules and review records follow every revision.

Client profile
automotive perception team
Task
2D / 3D object and track associations
setup
6 cameras + 1 LiDAR
Scope
12 sequences, each with 100 synchronized keyframe groups

02 / SCENE COVERAGE

Four road scenarios. One association rule set.

Keep each scene’s scope and review focus visible. Select a group to explore the breakdown: 12 sequences and 1,200 synchronized keyframe groups in total.

JUNCTIONS

Junctions

Turning vehicles, pedestrians and roadside occlusion occur together. Review identity consistency across multiple views.

Sequences
4
Keyframe groups
400

Review focus

  • Object references across cameras and LiDAR
  • Track continuity and termination around occlusion
  • Near-range boundaries and orientation

Example recordSEQ-J01 / KF-042 · Check the association ID for a turning vehicle across adjacent views.

Four scenes cover 12 sequences and 1,200 synchronized keyframe groups, organized by sequence and rule version.

03 / WORKING METHOD

Turn difficult scenes into explicit review tasks.

Align rules with representative examples, then annotate, review and revise by sequence. Every issue leads back to a scene and a rule version.

DECISION / 01

Objects can be mismatched across sensors

01 / THE APPROACH

Verify timing and coordinate references, then link images, point clouds and tracks with object IDs. Keep ambiguous links pending.

02 / THE REVIEW TRAILTimestamps, object IDs, calibration versions and association tables
DECISION / 02

Occlusion and low light obscure boundaries

01 / THE APPROACH

Use edge cases to align visibility and occlusion rules. Record uncertainty according to the rules instead of filling gaps by guesswork.

02 / THE REVIEW TRAILRule versions, example notes and issue locations
DECISION / 03

Revisions need a fresh review

01 / THE APPROACH

Return each issue to its sequence and keyframe group. Record the initial check, rework and recheck separately.

02 / THE REVIEW TRAILIssue IDs, revision references, recheck decisions and unresolved items

04 / REVIEW RECORD

Record the corrections. Keep open issues visible.

This stratified review covers 120 groups: 30 from each scene, so sampling fractions differ with scene size. The other 1,080 groups are uninspected and excluded from every pass rate.

Review sample120groups / 1,200 total
Initial pass95.8%115 / 120 sampled groups
Recheck pass80.0%4 / 5 reworked groups
Currently passed99.2%119 / 120 sampled groups
AUTO-001 · review ledger
SceneSampledInitial passRecheck pass / reworkCurrently passed
Junctions30291 / 130
Night & backlight30281 / 229
Roadworks30291 / 130
Mixed traffic30291 / 130
Total1201154 / 5119

Rates apply to the stated review sample. Batch acceptance follows agreed criteria; the 1,080 uninspected groups are tracked separately.

Explore delivery and quality

05 / HANDOVER STRUCTURE

Align the data and the documentation.

Organize indexes, labels, rule versions and review records into one manifest for receipt, verification and iteration.

  1. 01

    Sequence and synchronization indexes

    Sequence IDs, timestamps, six image references and one point-cloud reference, grouped by scenario.

  2. 02

    Labels and cross-modal associations

    2D / 3D objects, track IDs and association tables organized against an agreed rule version.

  3. 03

    Calibration and rule references

    Sensor setup, coordinate and calibration versions, example notes and change records.

  4. 04

    Review and unresolved issues

    Sample denominators, initial and recheck decisions, revision references and open issues.

LET’S DEFINE YOUR DATA TASK

Start with your scenarios and rules.

Describe your sensor setup, scene scope and expected outputs to frame a suitable pilot task.