Grasping tasks
8Label approach, contact, grasp and lift stages with their target objects.
PROJECT FOCUS / ROB-001
Robotics & embodied AI · Case study
Link visual, depth and state records across tabletop grasping, transfer and return tasks, defining action stages, object identities and observable outcomes.
← Back to case studies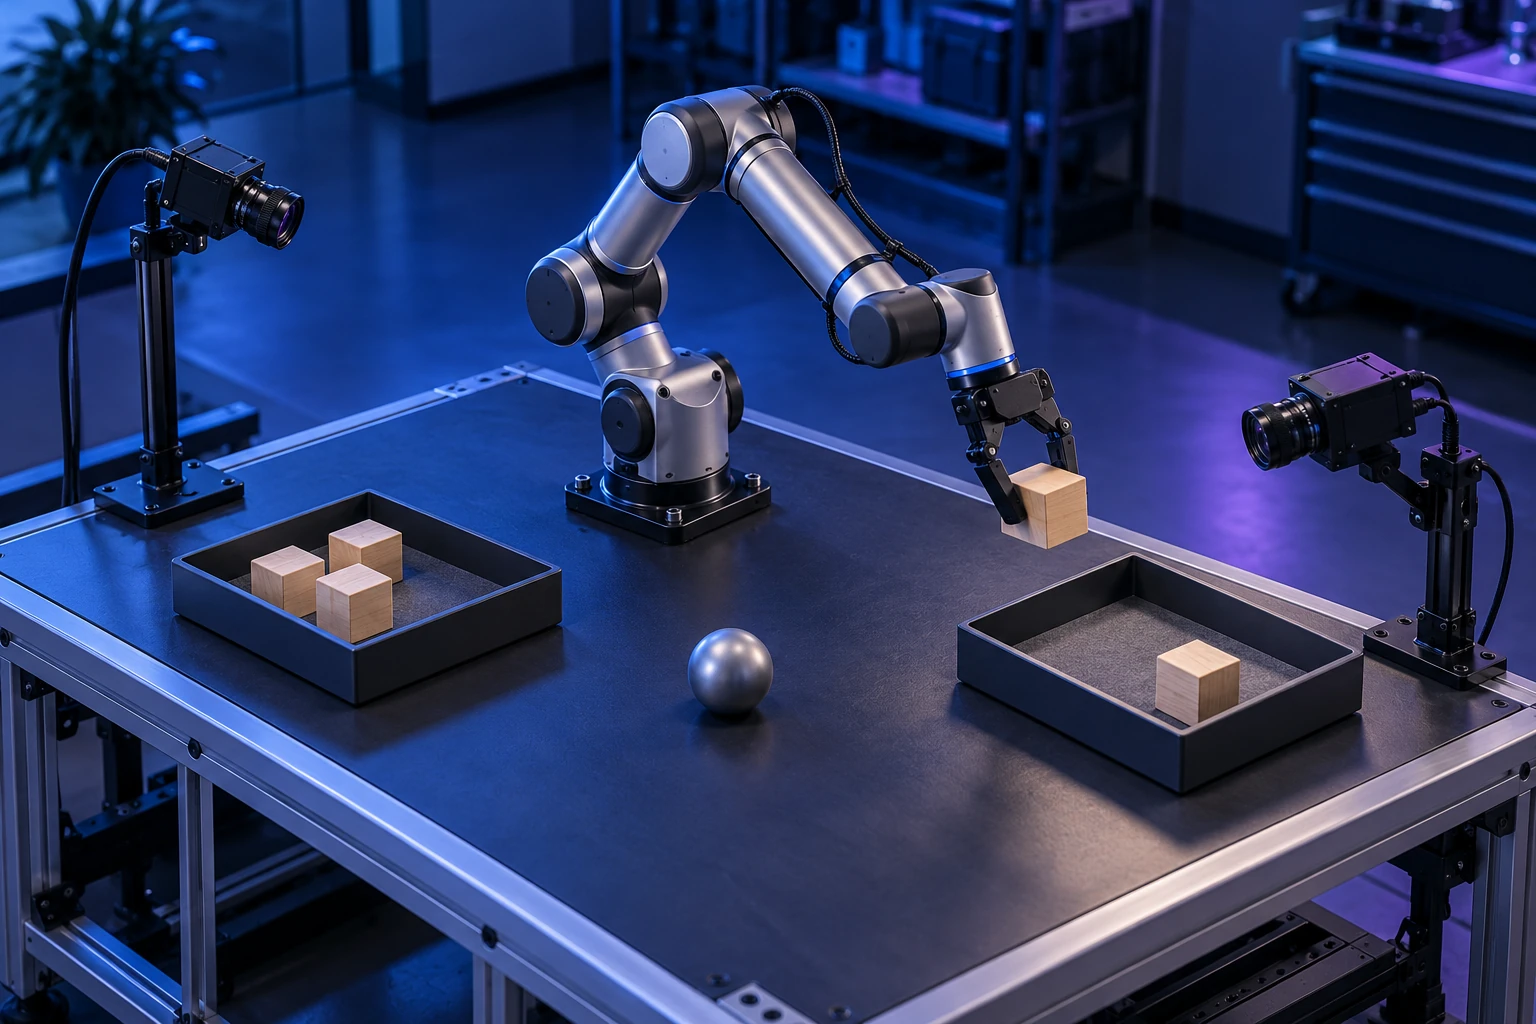
THE BRIEF
Build traceable sequences for manipulation understanding. Organize data by complete task and retain observable completion, failure and interruption states, connecting objects, actions and time.
SCENE COVERAGE
Label approach, contact, grasp and lift stages with their target objects.
Connect pickup, movement, placement and release, retaining drops and interruptions.
Record start and target positions, action stages and observable outcomes.
FROM CHALLENGE TO METHOD
01 / THE APPROACH
Align stages using complete sequences and define observable conditions for contact, departure and release.
01 / THE APPROACH
Read timestamps and synchronization notes, check dropped frames and abnormal offsets, and retain unresolved association issues.
01 / THE APPROACH
Label observable completion, failure and interruption. Keep unknown causes unknown rather than inferring internal robot states.
REVIEW & HANDOVER
Check overlaps, gaps and ordering, documenting concurrent actions where needed.
Verify target identities and associations across frames and streams.
Split by complete sequence and check that segments from one task do not leak across sets.
Provide task types, objects, sensor records and coordinate conventions.
Organize stage boundaries, cross-modal indexes and outcome labels.
Record dropped frames, time offsets, uncertain outcomes and resolution evidence.
WHAT TO TAKE FORWARD
Define observable task stages before organizing multimodal links. Retaining failures and uncertainty is more useful than masking missing information with apparently complete labels.
MORE PROJECT PERSPECTIVES
YOUR NEXT DATA PROJECT
To frame a similar pilot, share: Task definitions, device and sensor records, time and coordinate conventions, representative sequences and target formats.